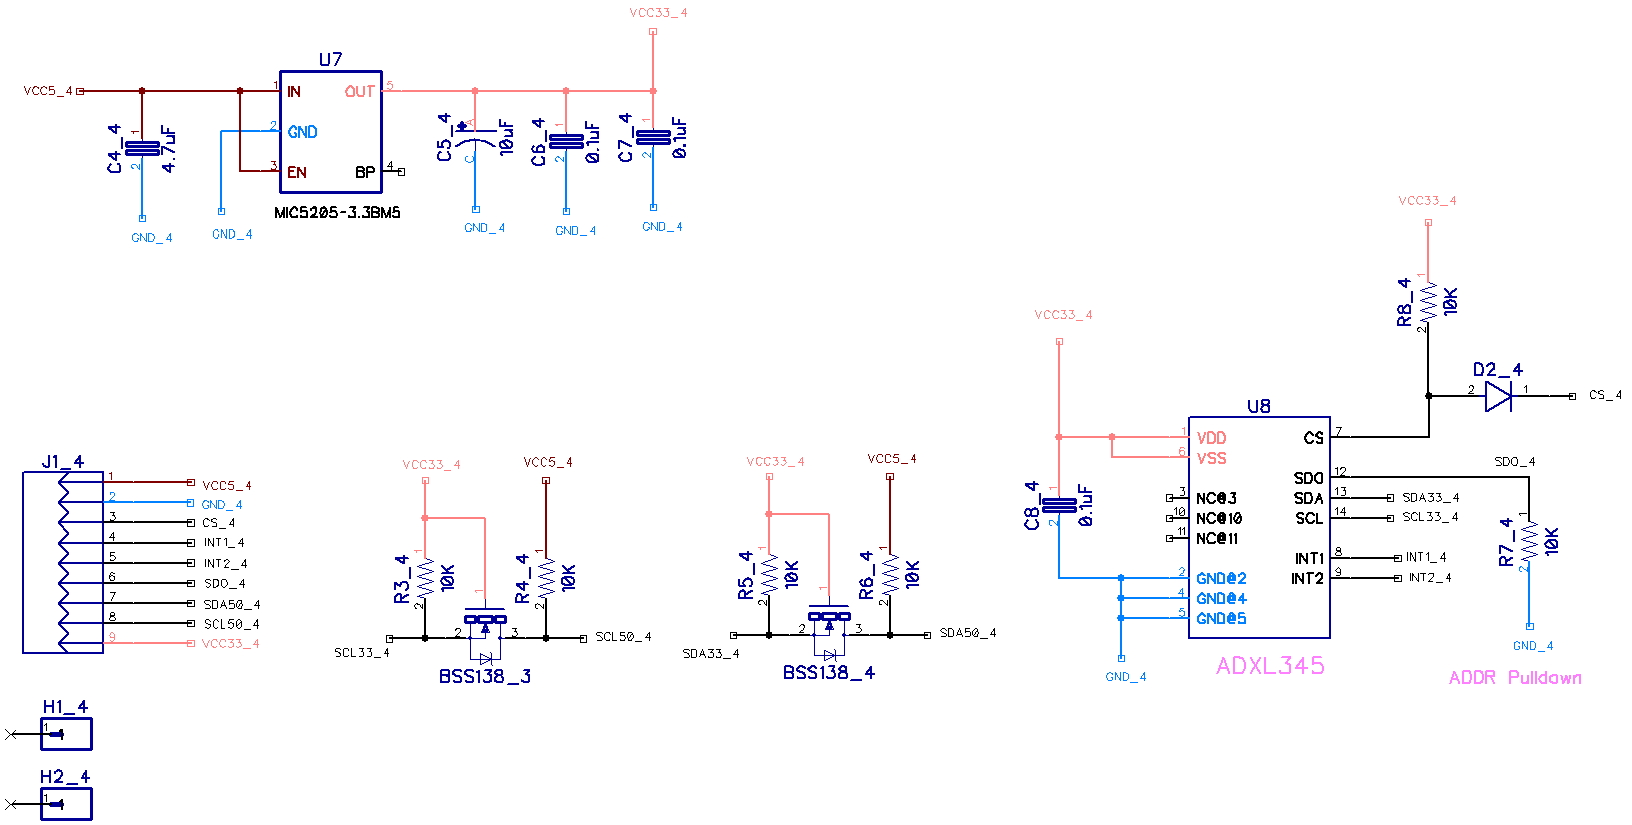
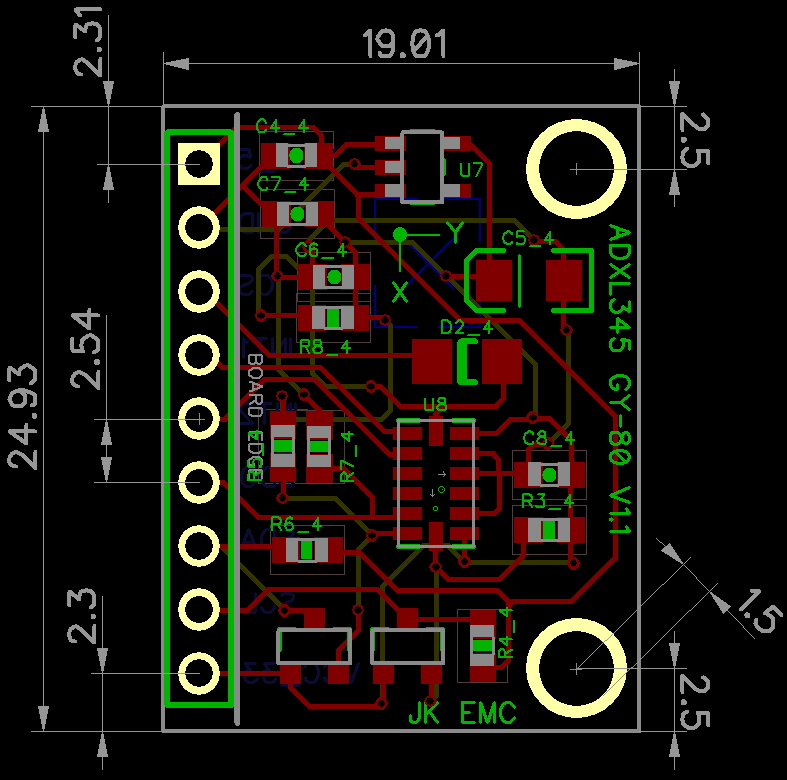
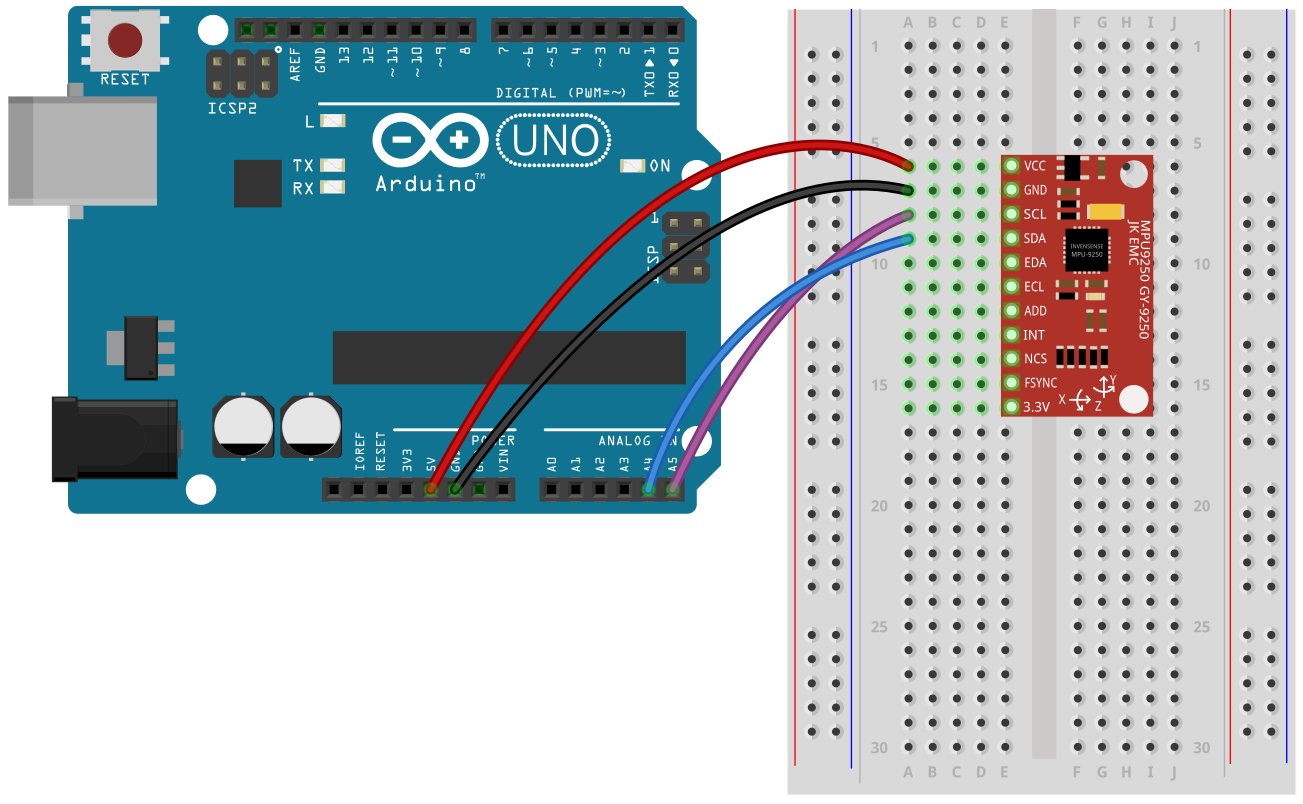
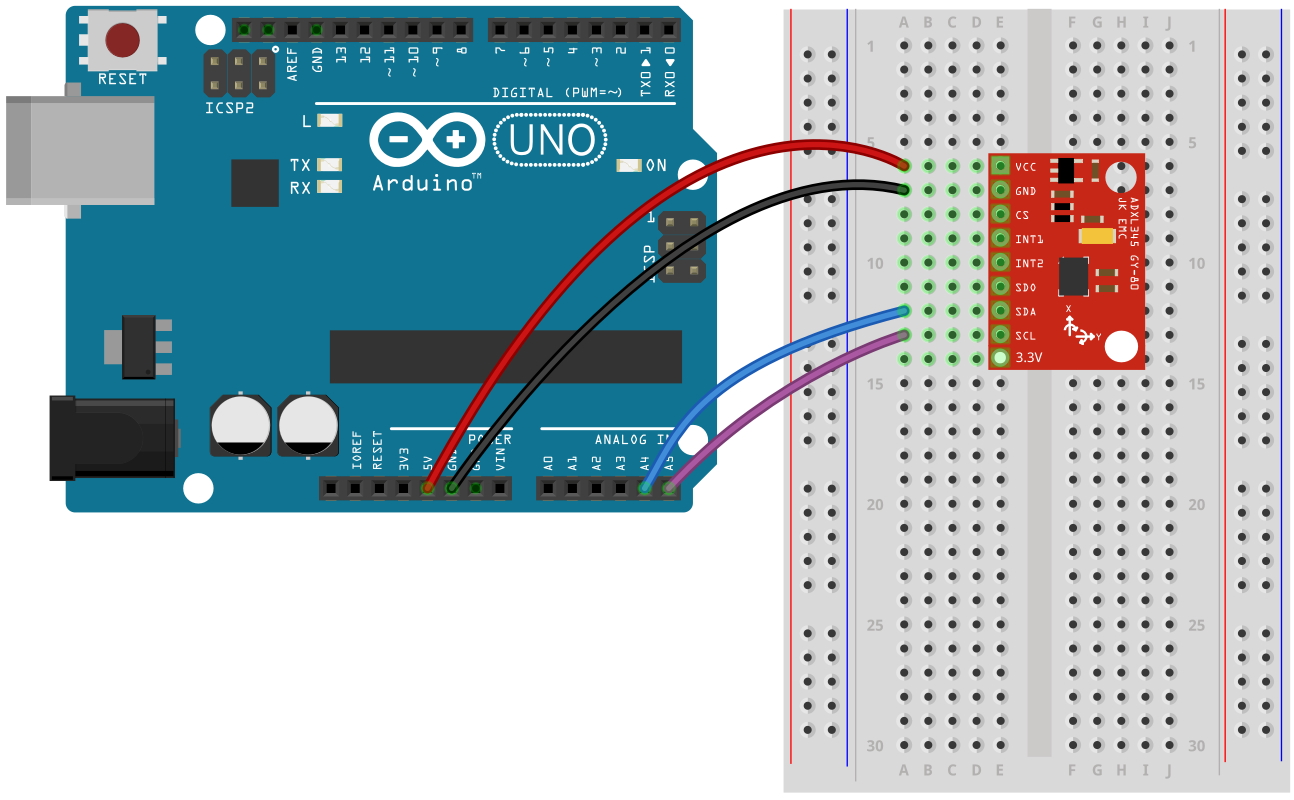
(1) 아두이노 UNO R3와 연결해서 가속도, 자이로 센터 데이터 출력 하기 본 제품은 내부에 회로적으로 3.3V전원
레듈레이터와 I2C 레벨쉬프터를 내장하고 있어서 5.0V와 3.3V 에서 모두 사용이 가능 하다. STM32, 라즈베리파이 등과
같이 3.3V 전원을 사용하는 프로세서에서 사용할 경우에는 VCC 대신에 3.3V 핀을 통해서 전원을 바로 연결해 주면 된다.
// I2C device class (I2Cdev) demonstration Arduino sketch for ADXL345 class // 10/7/2011 by Jeff Rowberg <jeff@rowberg.net> // Updates should (hopefully) always be available at https://github.com/jrowberg/i2cdevlib // // Changelog: // 2011-10-07 - initial release /* ============================================ I2Cdev device library code is placed under the MIT license Copyright (c) 2011 Jeff Rowberg Permission is hereby granted, free of charge, to any person obtaining a copy of this software and associated documentation files (the "Software"), to deal in the Software without restriction, including without limitation the rights to use, copy, modify, merge, publish, distribute, sublicense, and/or sell copies of the Software, and to permit persons to whom the Software is furnished to do so, subject to the following conditions: The above copyright notice and this permission notice shall be included in all copies or substantial portions of the Software. THE SOFTWARE IS PROVIDED "AS IS", WITHOUT WARRANTY OF ANY KIND, EXPRESS OR IMPLIED, INCLUDING BUT NOT LIMITED TO THE WARRANTIES OF MERCHANTABILITY, FITNESS FOR A PARTICULAR PURPOSE AND NONINFRINGEMENT. IN NO EVENT SHALL THE AUTHORS OR COPYRIGHT HOLDERS BE LIABLE FOR ANY CLAIM, DAMAGES OR OTHER LIABILITY, WHETHER IN AN ACTION OF CONTRACT, TORT OR OTHERWISE, ARISING FROM, OUT OF OR IN CONNECTION WITH THE SOFTWARE OR THE USE OR OTHER DEALINGS IN THE SOFTWARE. =============================================== */ // Arduino Wire library is required if I2Cdev I2CDEV_ARDUINO_WIRE implementation // is used in I2Cdev.h #include "Wire.h" // I2Cdev and ADXL345 must be installed as libraries, or else the .cpp/.h files // for both classes must be in the include path of your project #include "I2Cdev.h" #include "ADXL345.h" // class default I2C address is 0x53 // specific I2C addresses may be passed as a parameter here // ALT low = 0x53 (default for SparkFun 6DOF board) // ALT high = 0x1D ADXL345 accel; int16_t ax, ay, az; #define LED_PIN 13 // (Arduino is 13, Teensy is 6) bool blinkState =false; voidsetup() { // join I2C bus (I2Cdev library doesn't do this automatically) Wire.begin(); // initialize serial communication // (38400 chosen because it works as well at 8MHz as it does at 16MHz, but // it's really up to you depending on your project) Serial.begin(9600); // initialize device Serial.println("Initializing I2C devices..."); accel.initialize(); // verify connection Serial.println("Testing device connections..."); Serial.println(accel.testConnection() ?"ADXL345 connection successful":"ADXL345 connection failed"); // configure LED for output pinMode(LED_PIN, OUTPUT); } voidloop() { // read raw accel measurements from device accel.getAcceleration(&ax, &ay, &az); // display tab-separated accel x/y/z values Serial.print("accel:\t"); Serial.print(ax); Serial.print("\t"); Serial.print(ay); Serial.print("\t"); Serial.println(az); // blink LED to indicate activity blinkState =!blinkState; digitalWrite(LED_PIN, blinkState); }
ADXL345의 Slave Address는 기본적으로 0x53이고 본 제품에서도 AD0핀이 회로적으로 풀 다운 되어있다.
만약 ADXL345의 AD0핀을 풀업(VCC 3.3V 에 연결)을 시킨다면 Slave Address를 0x1D로 수정 하여야
한다.
#define ADXL345_ADDRESS_ALT_LOW 0x53
ADXL345 센서를 아두이노나 다른 마이크로 프로세서에서 동시에 2개를 사용해야 한다면 1개는 풀다운 그대로 사용을 하고
나머지
한개를 풀업 시켜서 Slave Address를 다르게 해서 사용을 하면 된다.
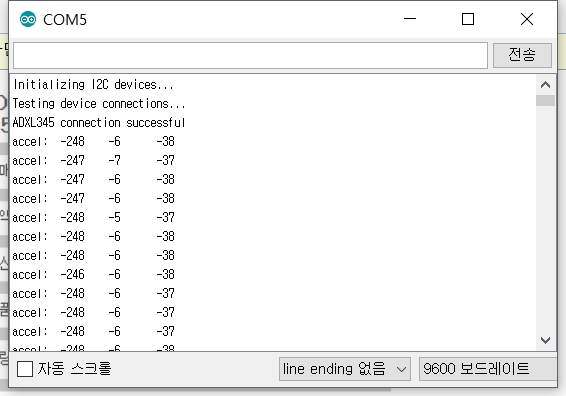
(2) 실행 결과
ADXL345과의 I2C 통신 상태를 검사하고 3축의 센서 출력 값을 반복해서 보여준다.
/******************************************************************************** * ADXL345 Library Examples- pitch_roll.ino * * * * Copyright (C) 2012 Anil Motilal Mahtani Mirchandani(anil.mmm@gmail.com) * * * * License GPLv3+: GNU GPL version 3 or later <http://gnu.org/licenses/gpl.html> * * This is free software: you are free to change and redistribute it. * * There is NO WARRANTY, to the extent permitted by law. * * * *********************************************************************************/ #include <Wire.h> #include "adxl345.h" constfloat alpha =0.5; double fXg =0; double fYg =0; double fZg =0; ADXL345 acc; voidsetup() { acc.begin(); Serial.begin(9600); delay(100); } voidloop() { double pitch, roll, Xg, Yg, Zg; acc.read(&Xg, &Yg, &Zg); //Low Pass Filter fXg = Xg * alpha + (fXg * (1.0- alpha)); fYg = Yg * alpha + (fYg * (1.0- alpha)); fZg = Zg * alpha + (fZg * (1.0- alpha)); //Roll & Pitch Equations roll = (atan2(-fYg, fZg)*180.0)/M_PI; pitch = (atan2(fXg, sqrt(fYg*fYg + fZg*fZg))*180.0)/M_PI; Serial.print(pitch); Serial.print(":"); Serial.println(roll); delay(10); }
아두이노 시리얼 모니터창에서 반드시 보드레이트(Baudate)를 9600 으로 수정 해야 한다. 그렇지
않으면 시리얼 모니터 창에 아무런 데이터가 표시되지 않거나 잘못된 데이터가 표시될 것이다. 프로세싱 데이터를 처리하기 위한
데이터 이므로 데이터를 바로 판독하기는 어렵다. 데이터가 올바르게 표시되는것을 확인 하였다면 프로세싱에서 동일한 시리얼포트를
사용해야 하기 때문에 아두이노 시리얼 모니텅 창을 닫도록 하자.
3.4
프로세싱 코드(3D)
프로세싱 코드에서 한가지 주의 해야할 사항은 시리얼 포트를 각자의 환경에 맞추어서 수정을 해주어야 한다는 것이다.
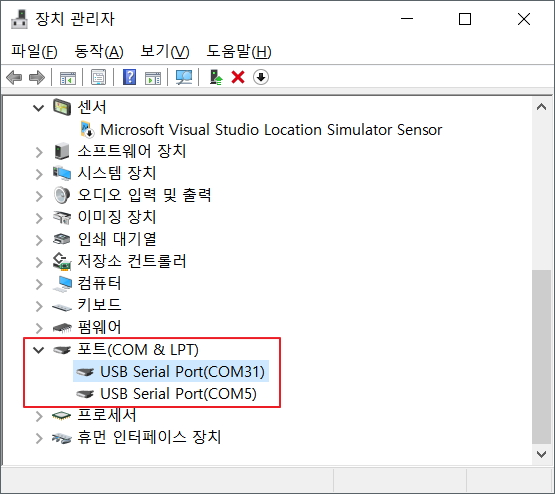
아래 프로세싱 코드에서 "[0]" 의 0이라는 숫자는 장치관리자에서 COM포트의 번호가 아니라 포트의 순서라는것에 주의 해야 한다.
위의 장치관리자 화면에서 예를 든다면 다음과 같다.
Serial.list()[0]; // --> COM31
Serial.list()[1]; // --> COM5

프로세싱 코드를 실행할때 테스트하는 PC의 COM 포트 상태에 따라서 "Serial.list()[0]" 의 숫자를 바꾸어 주어야 한다.
(1) 프로세싱 코드
/******************************************************************************** * ADXL345 Library Examples- pitch_roll.pde * * * * Copyright (C) 2012 Anil Motilal Mahtani Mirchandani(anil.mmm@gmail.com) * * * * License GPLv3+: GNU GPL version 3 or later <http://gnu.org/licenses/gpl.html> * * This is free software: you are free to change and redistribute it. * * There is NO WARRANTY, to the extent permitted by law. * * * *********************************************************************************/ // If you are working with Arduino Mega // sudo ln -s /dev/ttyACM0 /dev/ttyS8 import processing.serial.*; Serial fd; int pitch =0; int roll =0; voidsetup () { size(640, 360, P3D); //Connect to the corresponding serial port fd =new Serial(this, Serial.list()[0], 9600); // Defer callback until new line fd.bufferUntil('\n'); } voiddraw () { //Set background background(0.5); pushMatrix(); translate(width/2, height/2, -30); //Rotate rotateX(((float)pitch)*PI/180.0); rotateZ(((float)roll)*PI/180.0); //Print data print("Pitch: "); print(pitch); print(", Roll: "); println(roll); scale(90); beginShape(QUADS); fill(0, 255, 0); vertex(-1, 1, 1); fill(0, 255, 0); vertex( 1, 1, 1); fill(0, 255, 0); vertex( 1, -1, 1); fill(0, 255, 0); vertex(-1, -1, 1); fill(0, 255, 255); vertex( 1, 1, 1); fill(0, 255, 255); vertex( 1, 1, -1); fill(0, 255, 255); vertex( 1, -1, -1); fill(0, 255, 255); vertex( 1, -1, 1); fill(255, 0, 255); vertex( 1, 1, -1); fill(255, 0, 255); vertex(-1, 1, -1); fill(255, 0, 255); vertex(-1, -1, -1); fill(255, 0, 255); vertex( 1, -1, -1); fill(255, 255, 0); vertex(-1, 1, -1); fill(255, 255, 0); vertex(-1, 1, 1); fill(255, 255, 0); vertex(-1, -1, 1); fill(255, 255, 0); vertex(-1, -1, -1); fill(255, 0, 0); vertex(-1, 1, -1); fill(255, 0, 0); vertex( 1, 1, -1); fill(255, 0, 0); vertex( 1, 1, 1); fill(255, 0, 0); vertex(-1, 1, 1); fill(0, 0, 255); vertex(-1, -1, -1); fill(0, 0, 255); vertex( 1, -1, -1); fill(0, 0, 255); vertex( 1, -1, 1); fill(0, 0, 255); vertex(-1, -1, 1); endShape(); popMatrix(); } voidserialEvent (Serial fd) { // get the ASCII string: String rpstr = fd.readStringUntil('\n'); if (rpstr != null) { String[] list = split(rpstr, ':'); pitch = ((int)float(list[0])); roll = ((int)float(list[1])); } }
/* ADXL345 Triple Axis Accelerometer. Output for ADXL345_processing.pde Read more: http://www.jarzebski.pl/arduino/czujniki-i-sensory/3-osiowy-akcelerometr-adxl345.html GIT: https://github.com/jarzebski/Arduino-ADXL345 Web: http://www.jarzebski.pl (c) 2014 by Korneliusz Jarzebski */ #include <Wire.h> #include "adxl345.h" ADXL345 accelerometer; voidsetup(void) { Serial.begin(115200); // Initialize ADXL345 if (!accelerometer.begin()) { delay(500); } // Set measurement range // +/- 2G: ADXL345_RANGE_2G // +/- 4G: ADXL345_RANGE_4G // +/- 8G: ADXL345_RANGE_8G // +/- 16G: ADXL345_RANGE_16G accelerometer.setRange(ADXL345_RANGE_16G); } voidloop(void) { // Read normalized values Vector norm = accelerometer.readNormalize(); // Low Pass Filter to smooth out data. 0.1 - 0.9 Vector filtered = accelerometer.lowPassFilter(norm, 0.15); // Calculate Pitch & Roll int pitch =-(atan2(norm.XAxis, sqrt(norm.YAxis*norm.YAxis + norm.ZAxis*norm.ZAxis))*180.0)/M_PI; int roll = (atan2(norm.YAxis, norm.ZAxis)*180.0)/M_PI; // Calculate Pitch & Roll (Low Pass Filter) int fpitch =-(atan2(filtered.XAxis, sqrt(filtered.YAxis*filtered.YAxis + filtered.ZAxis*filtered.ZAxis))*180.0)/M_PI; int froll = (atan2(filtered.YAxis, filtered.ZAxis)*180.0)/M_PI; // Output Serial.print(pitch); Serial.print(":"); Serial.print(roll); Serial.print(":"); // Output (filtered) Serial.print(fpitch); Serial.print(":"); Serial.print(froll); Serial.println(); }
아두이노 시리얼 모니터창에서 반드시 보드레이트(Baudate)를 115200 으로 수정 해야 한다. 그렇지
않으면 시리얼 모니터 창에 아무런 데이터가 표시되지 않거나 잘못된 데이터가 표시될 것이다. 프로세싱 데이터를 처리하기 위한
데이터 이므로 데이터를 바로 판독하기는 어렵다. 데이터가 올바르게 표시되는것을 확인 하였다면 프로세싱에서 동일한 시리얼포트를
사용해야 하기 때문에 아두이노 시리얼 모니텅 창을 닫도록 하자.
3.4
프로세싱 코드(2D)
(1) 프로세싱 코드
/* ADXL345 Triple Axis Accelerometer. Processing for ADXL345_processing.ino Read more: http://www.jarzebski.pl/arduino/czujniki-i-sensory/3-osiowy-akcelerometr-adxl345.html GIT: https://github.com/jarzebski/Arduino-ADXL345 Web: http://www.jarzebski.pl (c) 2014 by Korneliusz Jarzebski */ import processing.serial.*; Serial myPort; // Data samples int actualSample =0; int maxSamples =400; int sampleStep =1; boolean hasData =false; // Charts PGraphics pgChart; int[] colors = { #ff4444, #33ff99, #5588ff }; String[] pyrSeries = { "Pitch", "Roll" }; String[] compareSeries = { "Normal", "Filtered" }; // Data for accelerometer Pitch, Roll float[][] pyrValues =newfloat[2][maxSamples]; float[][] pyrValuesFiltered =newfloat[2][maxSamples]; // Data for compare float[][] pitchValues =newfloat[2][maxSamples]; float[][] rollValues =newfloat[2][maxSamples]; // Artificial Horizon PGraphics pgArtificialHorizon; PGraphics pgArtificialHorizonRing; PImage imgArtificialHorizon; PImage imgArtificialHorizonRing; int ahWidth =0; int ahHeight =0; int ahDiameter =0; int ahRadius =0; float ahKappa =0.5522847498; float ahRadiusKappa =0; voidsetup () { size(755, 550, P2D); background(0); // Init initArtificialHorizon(); // Serial myPort =new Serial(this, Serial.list()[0], 115200); myPort.bufferUntil(10); } voiddrawChart(String title, String[] series, float[][] chart, int x, int y, int h, boolean symmetric, boolean fixed, int fixedMin, int fixedMax, int hlines) { int actualColor =0; int maxA =0; int maxB =0; int maxAB =0; int min =0; int max =0; int step =0; int divide =0; if (fixed) { min = fixedMin; max = fixedMax; step = hlines; } else { if (hlines >2) { divide = (hlines -2); } else { divide =1; } if (symmetric) { maxA = (int)abs(getMin(chart)); maxB = (int)abs(getMax(chart)); maxAB = max(maxA, maxB); step = (maxAB *2) / divide; min =-maxAB-step; max = maxAB+step; } else { min = (int)(getMin(chart)); max = (int)(getMax(chart)); if ((max >=0) && (min <=0)) step = (abs(min) + abs(max)) / divide; if ((max <0) && (min <0)) step = abs(min - max) / divide; if ((max >0) && (min >0)) step = (max - min) / divide; if (divide >1) { min -= step; max += step; } } } pgChart = createGraphics((maxSamples*sampleStep)+50, h+60); pgChart.beginDraw(); // Draw chart area and title pgChart.background(0); pgChart.strokeWeight(1); pgChart.noFill(); pgChart.stroke(50); pgChart.rect(0, 0, (maxSamples*sampleStep)+49, h+59); pgChart.text(title, ((maxSamples*sampleStep)/2)-(textWidth(title)/2)+40, 20); // Draw chart description String Description[] =new String[chart.length]; int DescriptionWidth[] =newint[chart.length]; int DesctiptionTotalWidth =0; int DescriptionOffset =0; for (int j =0; j < chart.length; j++) { Description[j] =" "+series[j]+" = "; DescriptionWidth[j] += textWidth(Description[j]+"+000.00"); Description[j] += nf(chart[j][actualSample-1], 0, 2)+" "; DesctiptionTotalWidth += DescriptionWidth[j]; } actualColor =0; for (int j =0; j < chart.length; j++) { pgChart.fill(colors[actualColor]); pgChart.text(Description[j], ((maxSamples*sampleStep)/2)-(DesctiptionTotalWidth/2)+DescriptionOffset+40, h+50); DescriptionOffset += DescriptionWidth[j]; actualColor++; if (actualColor >= colors.length) actualColor =0; } // Draw H-Lines pgChart.stroke(100); for (float t = min; t <= max; t=t+step) { float line = map(t, min, max, 0, h); pgChart.line(40, h-line+30, (maxSamples*sampleStep)+40, h-line+30); pgChart.fill(200, 200, 200); pgChart.textSize(12); pgChart.text(int(t), 5, h-line+34); } // Draw data series pgChart.strokeWeight(2); for (int i =1; i < actualSample; i++) { actualColor =0; for (int j =0; j < chart.length; j++) { pgChart.stroke(colors[actualColor]); float d0 = chart[j][i-1]; float d1 = chart[j][i]; if (d0 < min) d0 = min; if (d0 > max) d0 = max; if (d1 < min) d1 = min; if (d1 > max) d1 = max; float v0 = map(d0, min, max, 0, h); float v1 = map(d1, min, max, 0, h); pgChart.line(((i-1)*sampleStep)+40, h-v0+30, (i*sampleStep)+40, h-v1+30); actualColor++; if (actualColor >= colors.length) actualColor =0; } } pgChart.endDraw(); image(pgChart, x, y); } voidinitArtificialHorizon() { imgArtificialHorizon = loadImage("artificialHorizon.png"); imgArtificialHorizonRing = loadImage("artificialHorizonRing.png"); ahWidth = imgArtificialHorizon.width -20; ahHeight = imgArtificialHorizon.height -20; ahDiameter = min(ahWidth, ahHeight); ahRadius = ahDiameter /2; ahRadiusKappa = ahRadius * ahKappa; } floatgetArtificialHorizon(float pitch) { return-sin(pitch)*ahRadius; } voiddrawScale(float offset, float[][] pyr) { float horizon; // Ground side horizon = getArtificialHorizon(radians(pyr[0][actualSample-1]) - offset * PI /180); pgArtificialHorizon.noFill(); pgArtificialHorizon.beginShape(); pgArtificialHorizon.vertex(ahRadius, 0); pgArtificialHorizon.stroke(255); pgArtificialHorizon.strokeWeight(2); pgArtificialHorizon.bezierVertex(ahRadius, horizon * ahKappa, ahRadiusKappa, horizon, 0, horizon); pgArtificialHorizon.bezierVertex( -ahRadiusKappa, horizon, -ahRadius, horizon * ahKappa, -ahRadius, 0); pgArtificialHorizon.endShape(); // Sky side horizon = getArtificialHorizon(radians(pyr[0][actualSample-1]) + offset * PI /180); pgArtificialHorizon.noFill(); pgArtificialHorizon.beginShape(); pgArtificialHorizon.vertex(ahRadius, 0); pgArtificialHorizon.stroke(0); pgArtificialHorizon.strokeWeight(2); pgArtificialHorizon.bezierVertex(ahRadius, horizon * ahKappa, ahRadiusKappa, horizon, 0, horizon); pgArtificialHorizon.bezierVertex( -ahRadiusKappa, horizon, -ahRadius, horizon * ahKappa, -ahRadius, 0); pgArtificialHorizon.endShape(); } voiddrawArtificialHorizon(int x, int y, float[][] pyr) { pgArtificialHorizon = createGraphics(ahWidth, ahHeight); pgArtificialHorizonRing = createGraphics(ahWidth+20, ahHeight+20); float horizon = getArtificialHorizon(radians(pyr[0][actualSample-1])); // pgArtificialHorizon.clear(); pgArtificialHorizon.beginDraw(); // Ground pgArtificialHorizon.translate(ahRadius, ahRadius); pgArtificialHorizon.rotate(radians(-pyr[1][actualSample-1])); pgArtificialHorizon.strokeWeight(0); pgArtificialHorizon.fill(40, 40, 40); pgArtificialHorizon.arc(0.0, 0.0, ahDiameter, ahDiameter, 0, 2* PI); // Sky pgArtificialHorizon.beginShape(); pgArtificialHorizon.fill(200, 200, 250); pgArtificialHorizon.strokeWeight(2); pgArtificialHorizon.stroke(255); pgArtificialHorizon.vertex(-ahRadius, 0); pgArtificialHorizon.bezierVertex(-ahRadius, -ahRadius-20, ahRadius, -ahRadius-20, ahRadius, 0); pgArtificialHorizon.bezierVertex(ahRadius, horizon * ahKappa, ahRadiusKappa, horizon, 0, horizon); pgArtificialHorizon.bezierVertex(-ahRadiusKappa, horizon, -ahRadius, horizon * ahKappa, -ahRadius, 0); pgArtificialHorizon.endShape(); // Scale drawScale(60, pyr); drawScale(50, pyr); drawScale(40, pyr); drawScale(30, pyr); drawScale(20, pyr); drawScale(10, pyr); pgArtificialHorizon.endDraw(); image(pgArtificialHorizon, x+10, y+10); image(imgArtificialHorizon, x, y); // Draw ring pgArtificialHorizonRing.beginDraw(); pgArtificialHorizonRing.clear(); pgArtificialHorizonRing.translate(130,130); pgArtificialHorizonRing.rotate(radians(pyr[1][actualSample-1])); pgArtificialHorizonRing.image(imgArtificialHorizonRing, -130, -130); pgArtificialHorizonRing.endDraw(); image(pgArtificialHorizonRing, x, y); } floatgetMin(float[][] chart) { float minValue =0; float[] testValues =newfloat[chart.length]; float testMin =0; for (int i =0; i < actualSample; i++) { for (int j =0; j < testValues.length; j++) { testValues[j] = chart[j][i]; } testMin = min(testValues); if (i ==0) { minValue = testMin; } else { if (minValue > testMin) minValue = testMin; } } return ceil(minValue)-1; } floatgetMax(float[][] chart) { float maxValue =0; float[] testValues =newfloat[chart.length]; float testMax =0; for (int i =0; i < actualSample; i++) { for (int j =0; j < testValues.length; j++) { testValues[j] = chart[j][i]; } testMax = max(testValues); if (i ==0) { maxValue = testMax; } else { if (maxValue < testMax) maxValue = testMax; } } return ceil(maxValue); } voiddraw() { if (!hasData) return; background(0); drawChart("Pitch [deg]", compareSeries, pitchValues, 10, 10, 200, true, true, -90, 90, 30); drawChart("Roll [deg]", compareSeries, rollValues, 10, 280, 200, true, true, -90, 90, 30); drawArtificialHorizon(480, 20, pyrValues); drawArtificialHorizon(480, 290, pyrValuesFiltered); } voidnextSample(float[][] chart) { for (int j =0; j < chart.length; j++) { float last = chart[j][maxSamples-1]; for (int i =1; i < maxSamples; i++) { chart[j][i-1] = chart[j][i]; } chart[j][(maxSamples-1)] = last; } } voidserialEvent (Serial myPort) { String inString = myPort.readStringUntil(10); if (inString != null) { inString = trim(inString); String[] list = split(inString, ':'); String testString = trim(list[0]); if (list.length !=4) return; // Fill Pitch & Roll pyrValues[0][actualSample] = (float(list[0])); pyrValues[1][actualSample] = (float(list[1])); // Fill Pitch & Roll (Filtered) pyrValuesFiltered[0][actualSample] = (float(list[2])); pyrValuesFiltered[1][actualSample] = (float(list[3])); // Fill Pitch compare pitchValues[0][actualSample] = (float(list[0])); pitchValues[1][actualSample] = (float(list[2])); // Fill Roll compare rollValues[0][actualSample] = (float(list[1])); rollValues[1][actualSample] = (float(list[3])); if (actualSample >1) { hasData =true; } if (actualSample == (maxSamples-1)) { nextSample(pyrValues); nextSample(pyrValuesFiltered); nextSample(pitchValues); nextSample(rollValues); } else { actualSample++; } } }